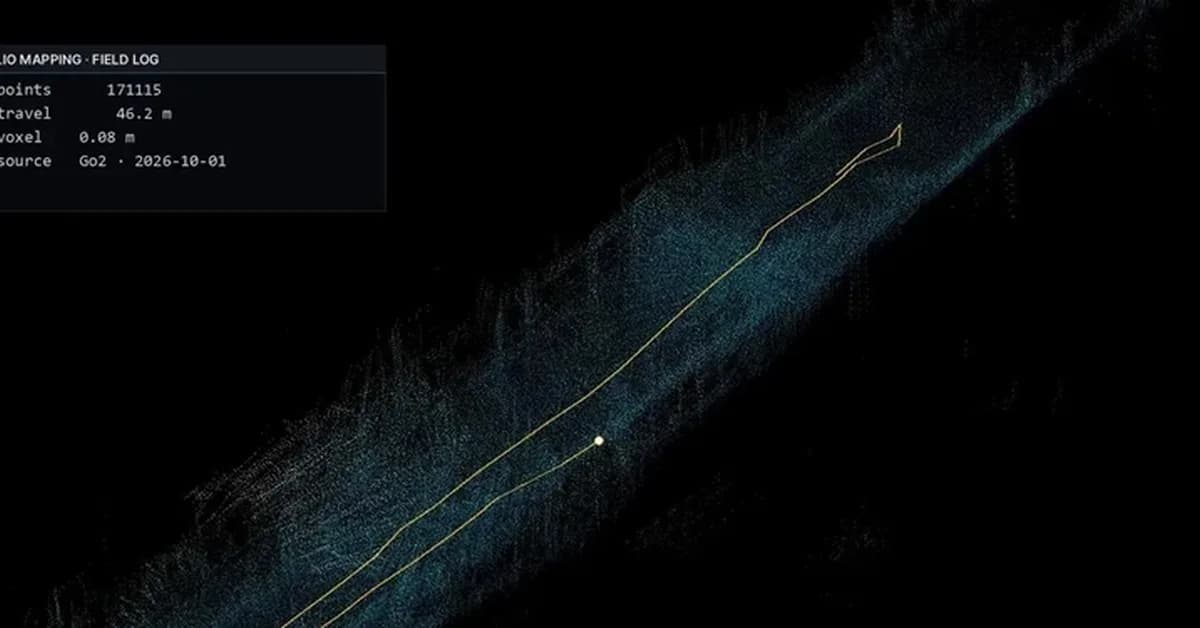
A complete mapping payload for robot dogs typically includes a Livox Mid-360 LiDAR, an IMU, a depth camera, and a Jetson Orin NX computer, all integrated onto a single adapter plate. This hardware setup is crucial for generating accurate maps that enable reliable localization and navigation, as the quality of the map directly impacts the robot's performance. The system emphasizes precise time synchronization between sensors and careful calibration to ensure map accuracy, and offline map rebuilding incorporates loop closure and dynamic object removal.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.
Views75

Ali NematiBlogUI.author_articles