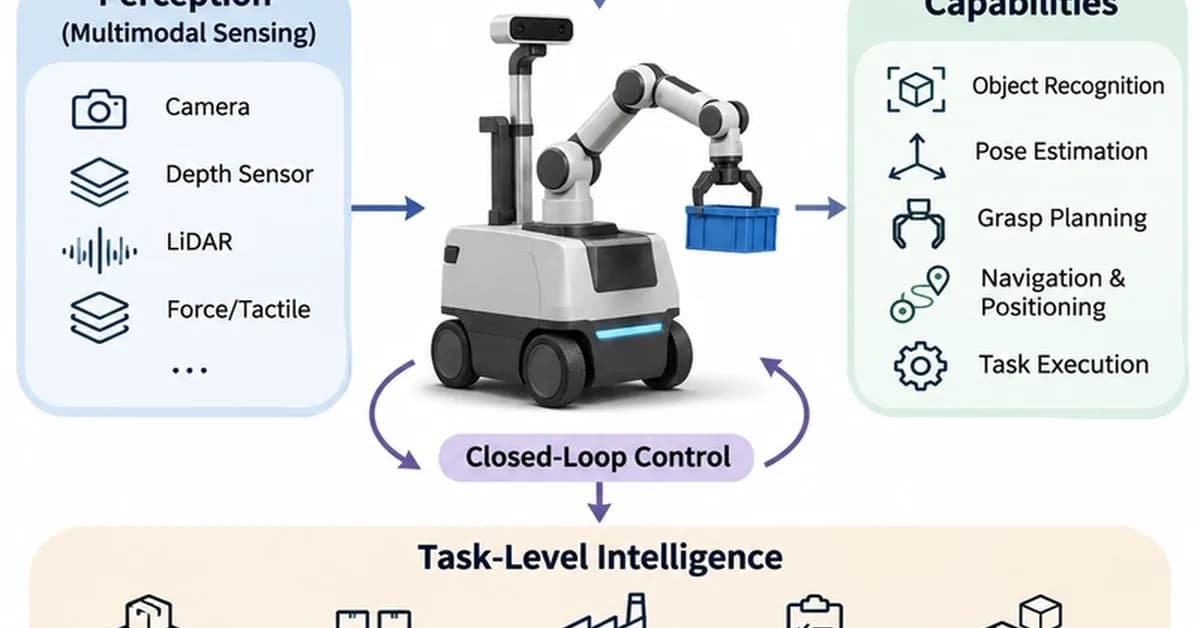
AI-driven manipulation represents a significant advancement for mobile robotics, shifting from pre-programmed systems to adaptive ones capable of complex tasks in dynamic environments. By integrating AI, mobile manipulators can enhance perception, scene understanding, and autonomous decision-making, moving beyond rigid trajectories and pre-defined workspaces. Key areas of development include deep learning for perception, reinforcement learning for adaptive behaviors, and multimodal sensor fusion for robust interaction.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.
Views74

Ali NematiBlogUI.author_articles