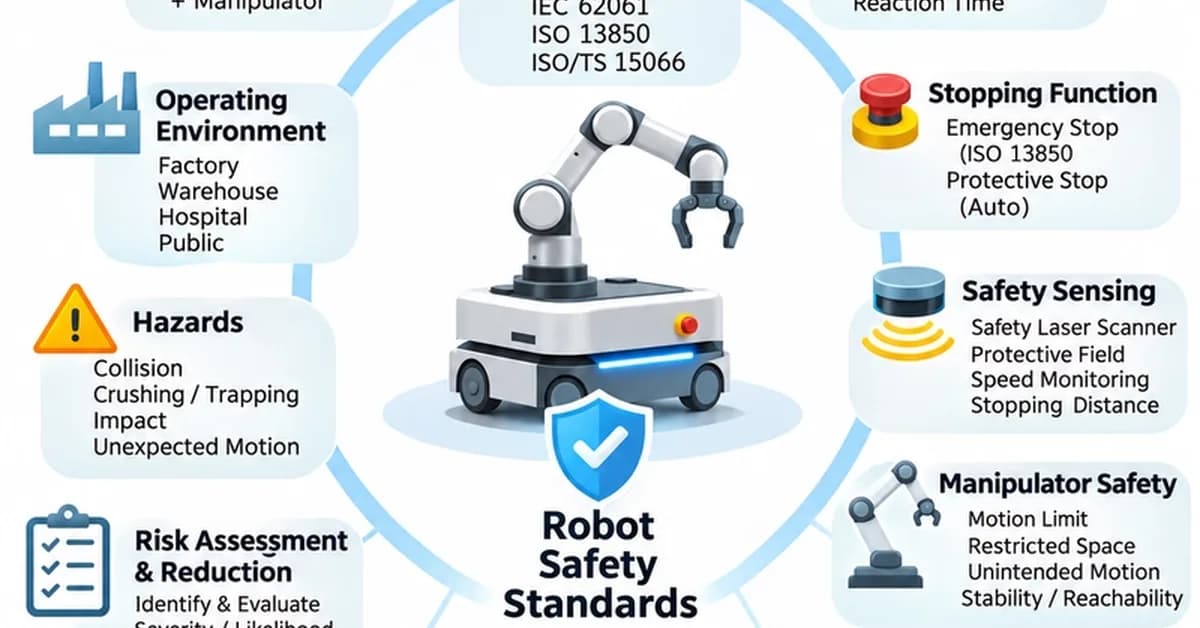
Robot safety standards are crucial for mobile manipulators, addressing risks from both autonomous navigation and articulated manipulation to protect people and property. Standards like ISO 12100 and ISO 10218 provide frameworks for risk assessment and reduction, while specific considerations for mobile robots involve collision avoidance and ensuring safe stopping distances. Functional safety principles are applied to control systems, emphasizing the need for validated safety functions and robust emergency stop mechanisms.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.
Views24

Ali NematiBlogUI.author_articles