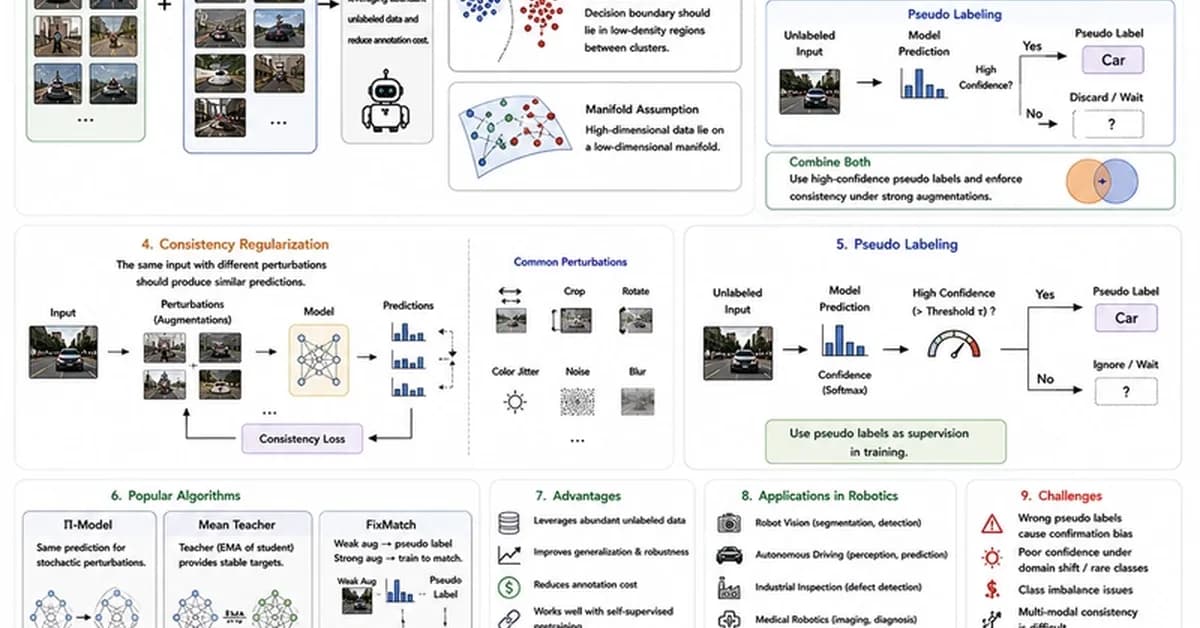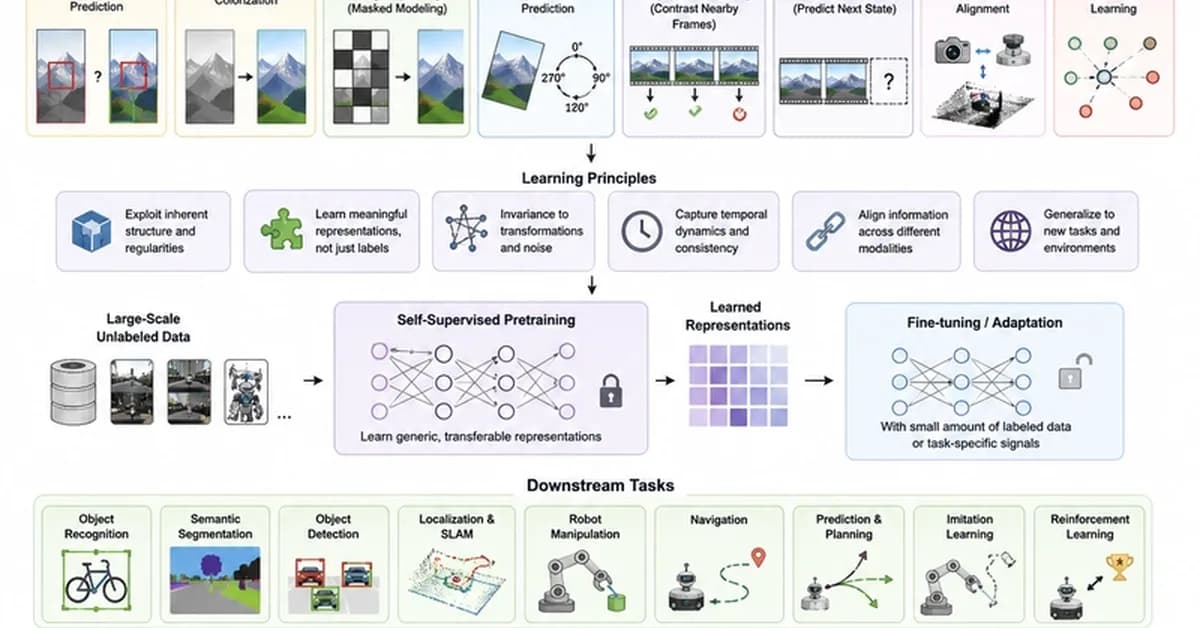
Contrastive learning has emerged as a pivotal self-supervised strategy for robotics, enabling models to learn robust visual representations without human labels by maximizing similarities between augmented views of the same data while minimizing differences across distinct samples. Techniques like SimCLR and MoCo allow robots to accumulate experience autonomously in dynamic environments, achieving strong generalization for tasks ranging from object detection to sensor fusion with minimal labeled data. This approach forms the foundation for next-generation physical AI capable of continuous adaptation and lifelong learning across diverse operational scenarios.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.