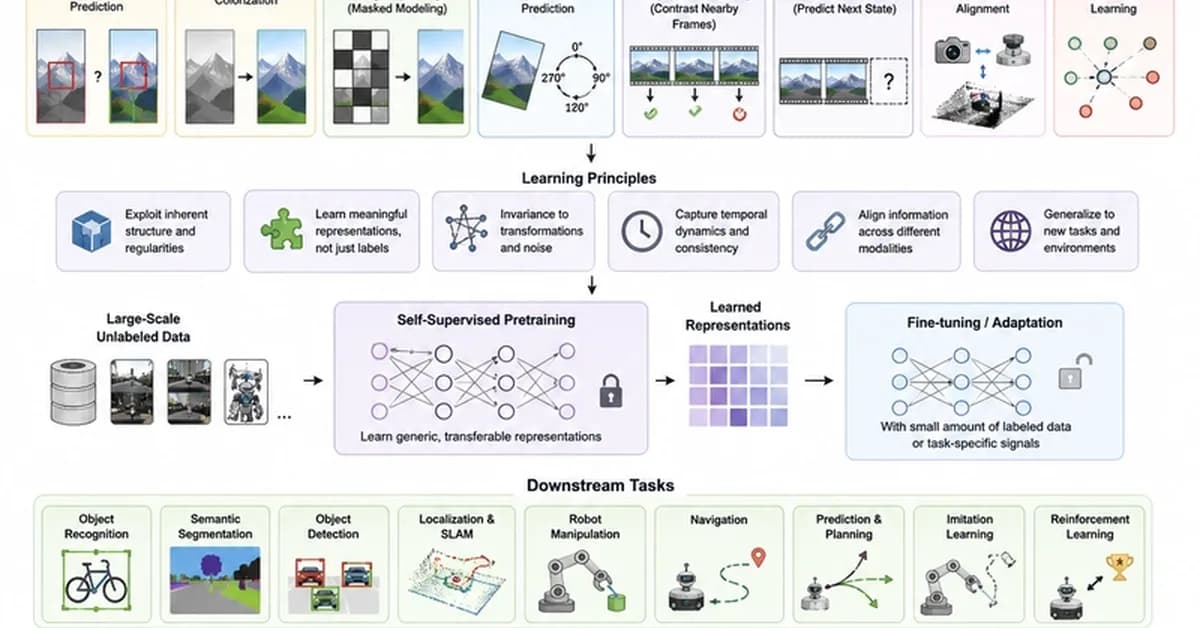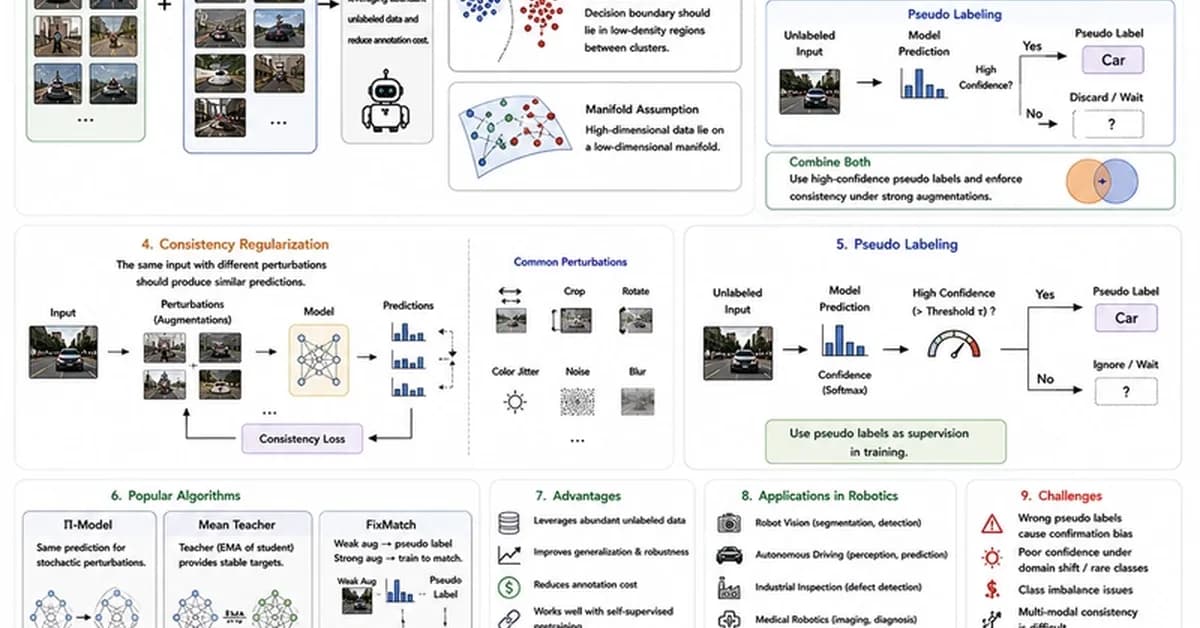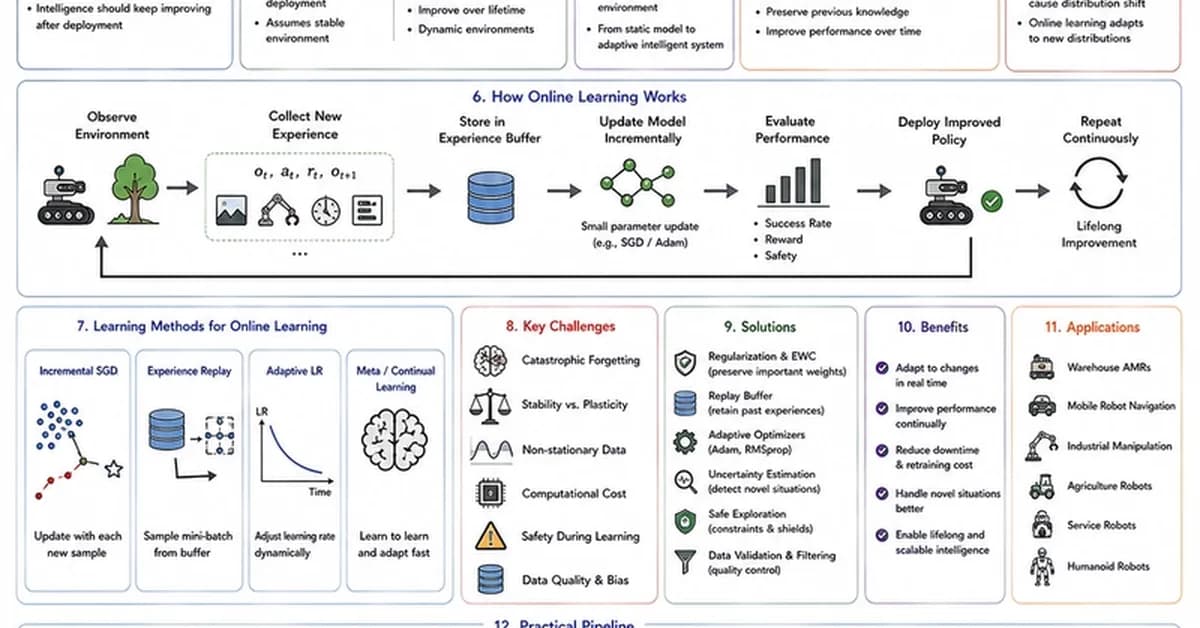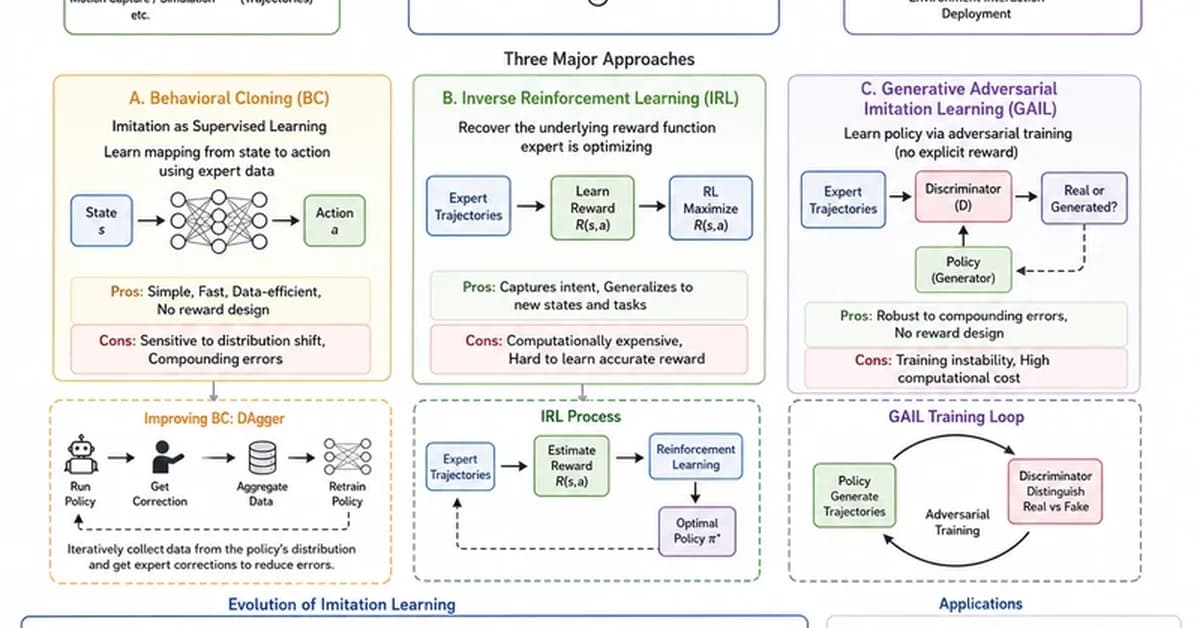
Imitation learning excels in robotics by leveraging high-quality expert demonstrations to generate safe and efficient control policies without costly trial-and-error exploration. However, its performance is strictly limited by data diversity and quality, as models cannot generalize beyond the conditions present in their training dataset. Consequently, successful deployment relies on rigorous sensor synchronization, extensive domain randomization, and careful handling of covariate shifts between simulation and reality.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.
Views64

Ali NematiBlogUI.author_articles