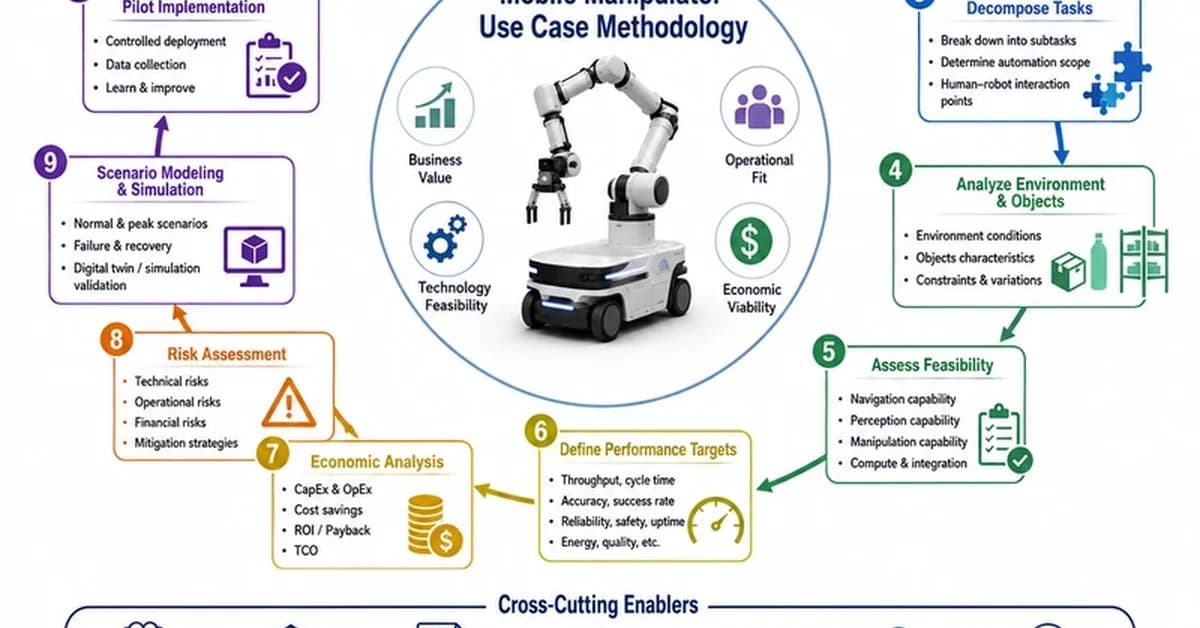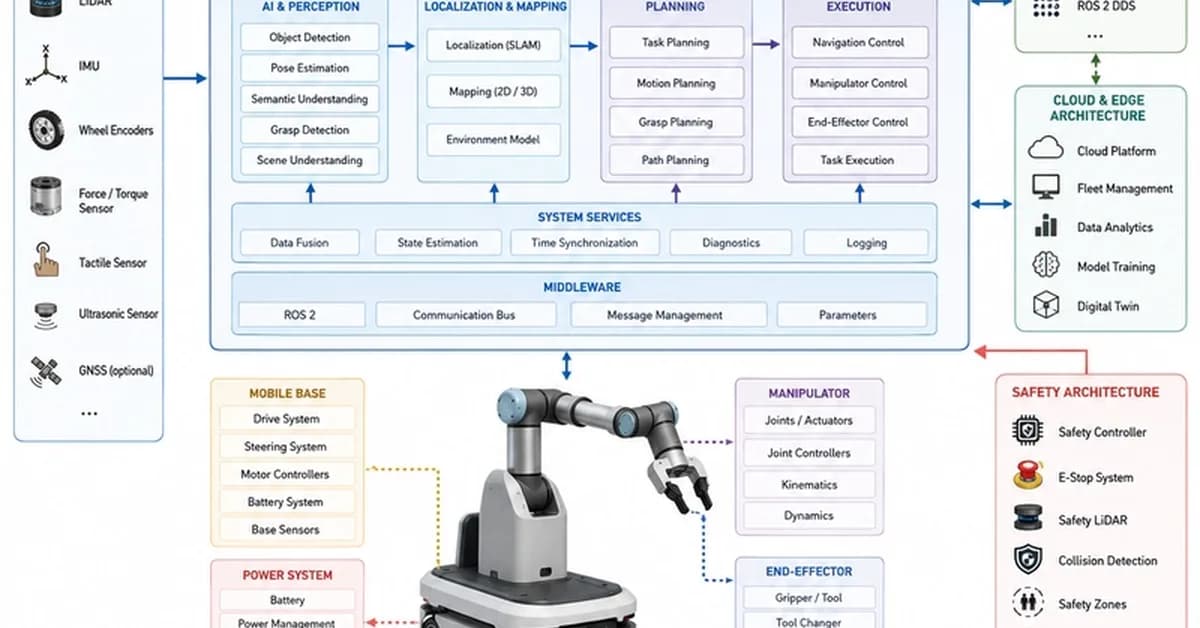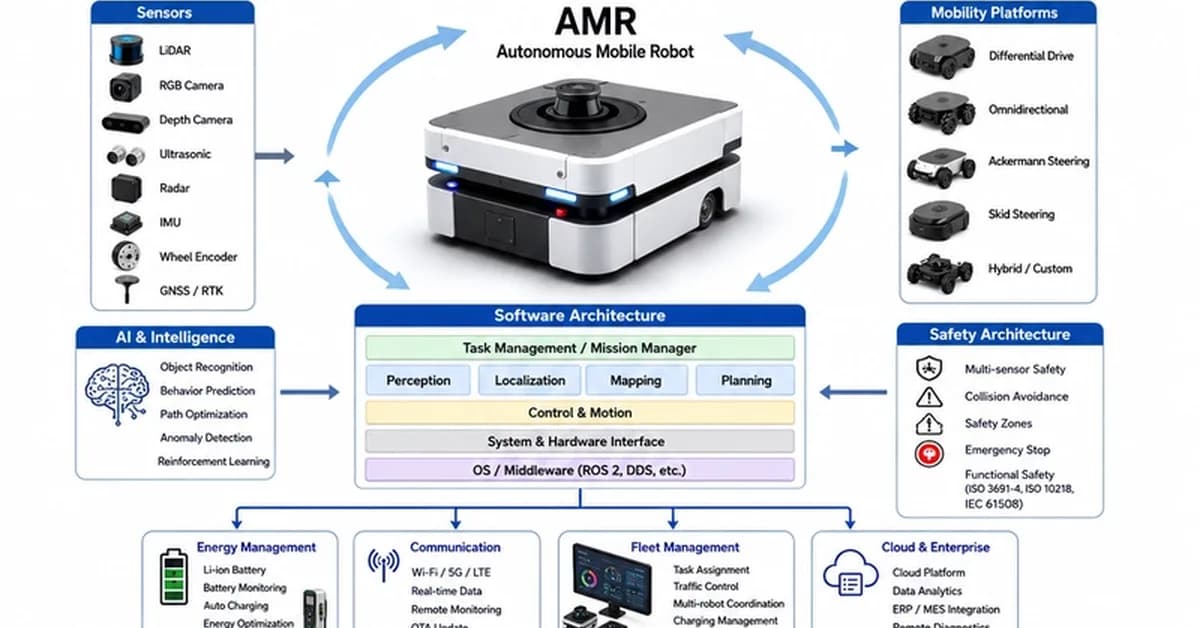
The convergence of Autonomous Mobile Robots (AMRs) and industrial robot arms is creating a new class of mobile manipulator systems, moving beyond traditional, stationary automation setups. This integration allows robots to autonomously navigate environments, interact with objects, and perform complex tasks, expanding applications across industries like logistics, healthcare, and manufacturing. This development highlights the increasing importance of tightly integrated navigation and manipulation, requiring advanced perception, planning, and control architectures, and signals a shift towards AI-powered robots capable of dynamic adaptation and natural language understanding.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.