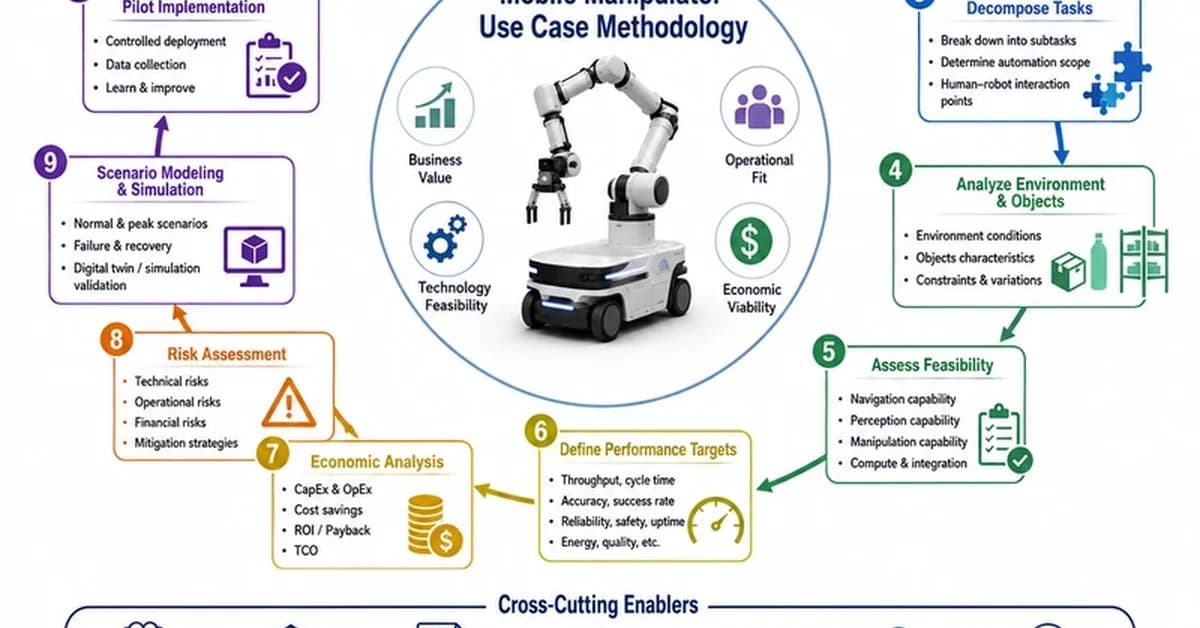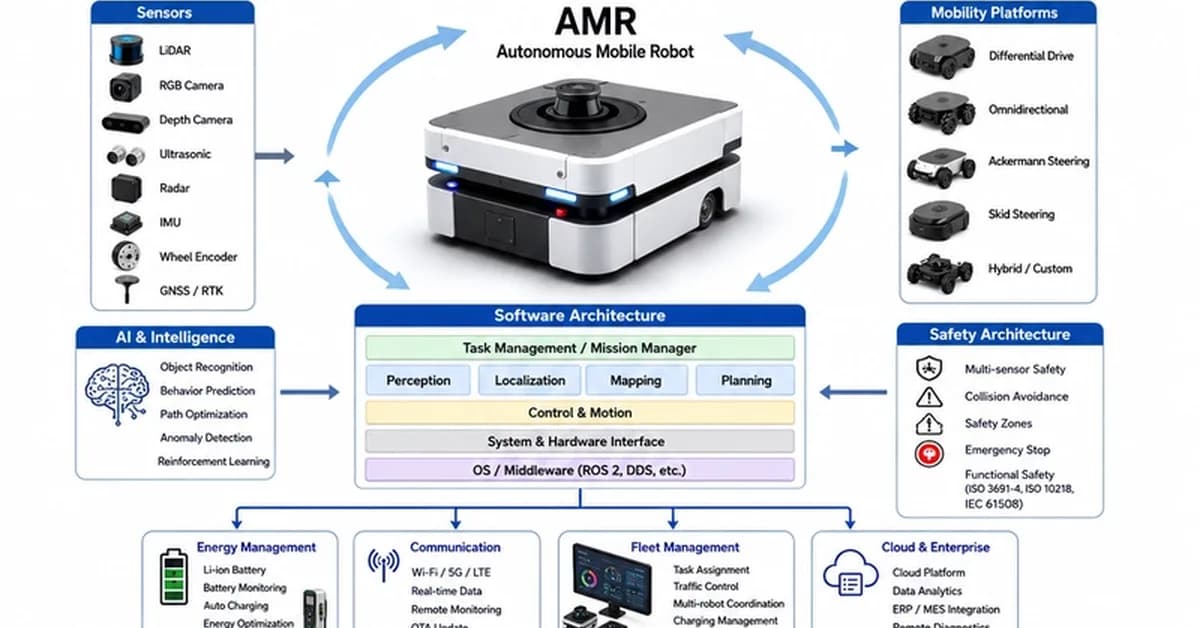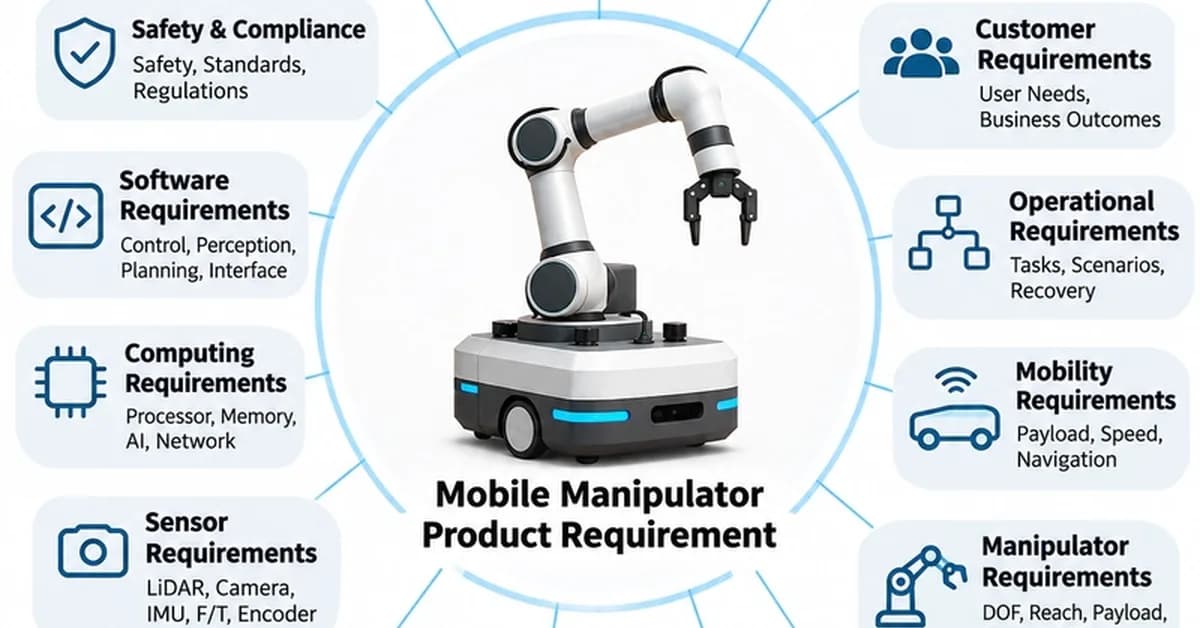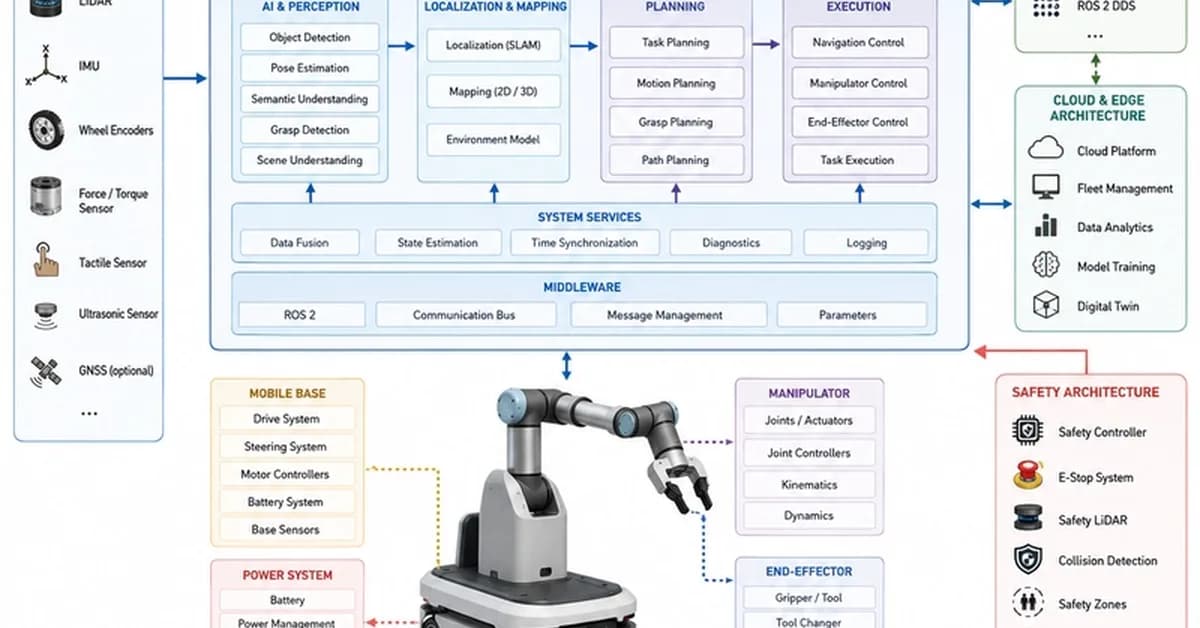
Mobile manipulators, robots combining autonomous mobility and robotic manipulation, represent a significant advancement in robotics, bridging the gap between AMRs and traditional industrial robots. The system architecture of these complex machines is crucial for integrating mechanical structures, electrical systems, sensing technologies, computing platforms, and AI into a unified, reliable operational framework. Understanding this architecture—which includes elements like sensor fusion, hierarchical control, and increasingly, AI-driven decision-making—is vital for engineers and researchers developing the next generation of intelligent robotic systems.
Read the full article at DEV Community
Want to create content about this topic? Use Nemati AI tools to generate articles, social posts, and more.

![Mobile Manipulator Foundations and System Architecture - Ch.03: System Architecture [EN]](/_next/image?url=https%3A%2F%2Fmedia.nemati.ai%2Fmedia%2Fblog%2Fimages%2Farticles%2Fe4b489a1bd324e0f.webp&w=3840&q=75)
![Mobile Manipulator Foundations and System Architecture - Ch.04: Use Cases [EN]](/_next/image?url=https%3A%2F%2Fmedia.nemati.ai%2Fmedia%2Fblog%2Fimages%2Farticles%2F05e913186e344989.webp&w=3840&q=75)
![Mobile Manipulator Foundations and System Architecture - Ch.02: AMR plus Robot Arm [EN]](/_next/image?url=https%3A%2F%2Fmedia.nemati.ai%2Fmedia%2Fblog%2Fimages%2Farticles%2F55ecdba274084916.webp&w=3840&q=75)
![Mobile Manipulator Foundations and System Architecture - Ch.17: Checklists and Templates [KR]](/_next/image?url=https%3A%2F%2Fmedia.nemati.ai%2Fmedia%2Fblog%2Fimages%2Farticles%2Fc3310a034d4a48dd.webp&w=3840&q=75)